Robotic Roll Handling
Coordinate repeatable roll pickup, orientation and placement where payload, reach and surface protection justify a robotic cell.
- Payload and reach validation
- Roll-specific end-effector review
- Guarded machine-to-station transfer
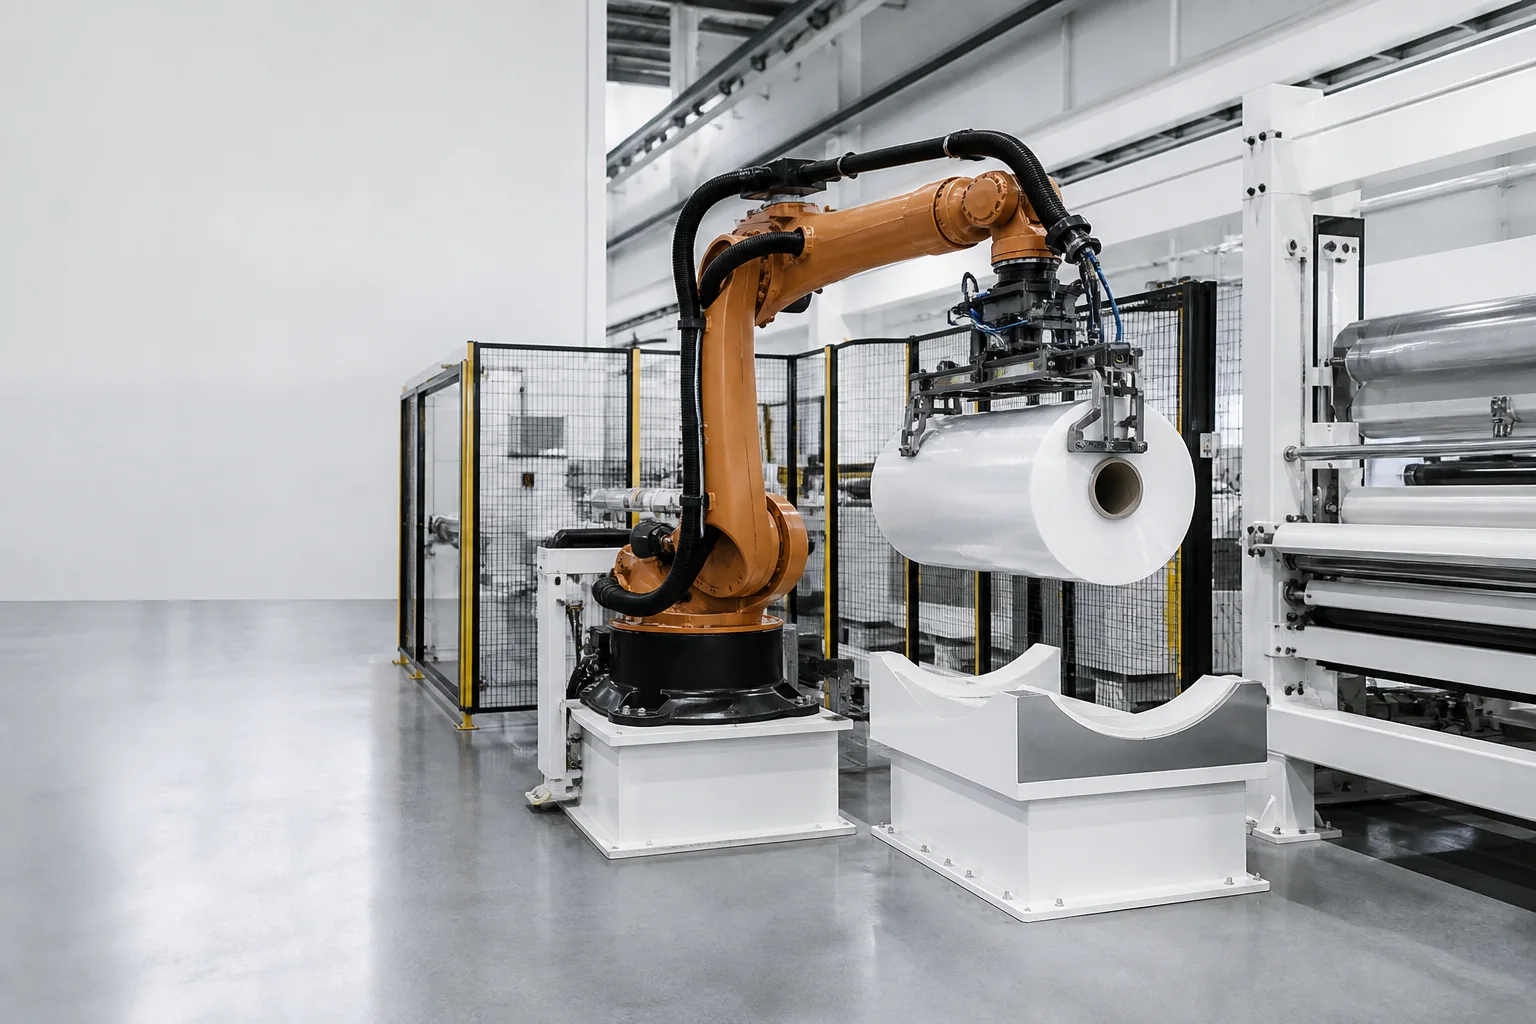
Use robotics where a defined roll transfer needs repeatability and orientation control
Robot selection begins with the load and cell, not the arm model. Roll weight, core access, surface sensitivity, pickup uncertainty, reach, cycle time and safe operator access define the feasible concept.
SlitForge structures the handling sequence and coordinates the review with the relevant robotics and converting-equipment suppliers. Final tooling, safety validation and performance commitments remain supplier-specific.
- Starting point
- A roll presented in a repeatable supported position
- Handling path
- Confirm, grip, lift, orient and place within a guarded cell
- Confirmation basis
- Payload, reach, end effector, cycle, interfaces and risk assessment
Four controlled actions define the robotic transfer
The end effector and presentation fixtures must keep the roll stable through every pose without unacceptable surface or core damage.
Confirm
Verify roll presence, pickup pose, destination readiness and cell permission.
Grip
Engage the approved core, shaft or external-support interface and confirm retention.
Move
Lift and orient the roll within validated payload, reach and collision limits.
Place
Seat the roll in the destination fixture and verify support before releasing the tool.
The robot cell is configured around the end effector and handoffs
- Robot payload, reach and mounting arrangement
- Core, shaft or external roll end effector
- Pickup and destination presentation fixtures
- Presence sensing and optional identification
- Machine PLC, cell controller and sequence interface
- Perimeter guarding, access control and safe recovery
Responsibility and acceptance points stay visible
End effector
Retention force, roll deformation risk and fail-safe behavior are confirmed for the load range.
Cell safety
Guarding, access, safe speed, restart and recovery are validated by the responsible integrator.
Acceptance criteria
Representative loads, poses, cycle timing and fault recovery are included in the test plan.
Review the machine interface before defining automation
Share the roll range, handoff points and cycle target
We will structure the robotic sequence and coordinate a supplier-confirmed feasibility review.